Avatar

Associate Professor in Artificial Intelligence

The University of Melbourne

Biography

I am an Associate Professor in Artificial Intelligence in the School of Computing and Information Systems, Faculty of Engineering and Information Technology, at The University of Melbourne (Australia), where I lead the Artificial Intelligence group. I serve as Course Director of the Master of Artificial Intelligence (Online), and as a member of the ICAPS Executive Council, where I am the Mentoring and Diversity Chair. My research and teaching interests span AI planning, search, learning, reasoning with large language models, intention recognition, and autonomous systems. I’m a member of the AI and Autonomous Agents Lab and the Digital Agriculture, Food and Wine lab.

My research focuses on how to introduce different approaches to the problem of inference in sequential decision problems, as well as applications to autonomous systems in agriculture.

I completed my PhD at the Artificial Intelligence and Machine Learning Group, Universitat Pompeu Fabra, under the supervision of Prof. Hector Geffner. I was a research fellow for 3 years under the supervision of Prof. Peter Stuckey and Prof. Adrian Pearce, working on solving Mining Scheduling problems through automated planning, constraint programming and operations research techniques. Since then, I have built a research program around width-based search and novelty, whose planners have been awarded in several International Planning Competitions, most recently winning the Satisficing and Agile tracks of the IPC 2026 Numeric Tracks. This program has grown to intersect with other areas, from goal and intention recognition with humans, to the integration of reasoning and learning, where planning meets machine learning and large language models.

Interests

  • AI planning
  • Search
  • Learning
  • Verification
  • Constraint Programming
  • Operations Research
  • Intention Recognition
  • Sequential Decision Problems
  • Autonomous Systems

Education

  • Graduate Certificate in University Teaching, 2020

    The University of Melbourne

  • PhD in Artificial Intelligence, 2012

    Universitat Pompeu Fabra

  • MEng in Artificial Intelligence, 2007

    Universitat Pompeu Fabra

  • BSc in Computer Science, 2004

    Universitat Pompeu Fabra
Projects

AI Planning Solvers Online

Planning as a Service (PaaS) is an extendable API to deploy planners online in local or cloud servers

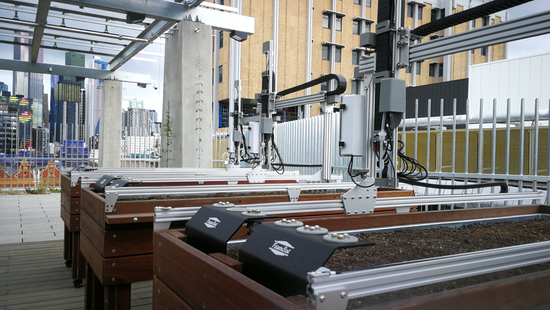
Farm.bot at The University of Melbourne

Farm.bot is an open-source robotic platform to explore problems on AI and Automation (Planning, Vision, Learning) for small scale …

Width Based Planning

Width Based Planning searches for solutions through a general measure of state novelty. Performs well over black-box simulators and …

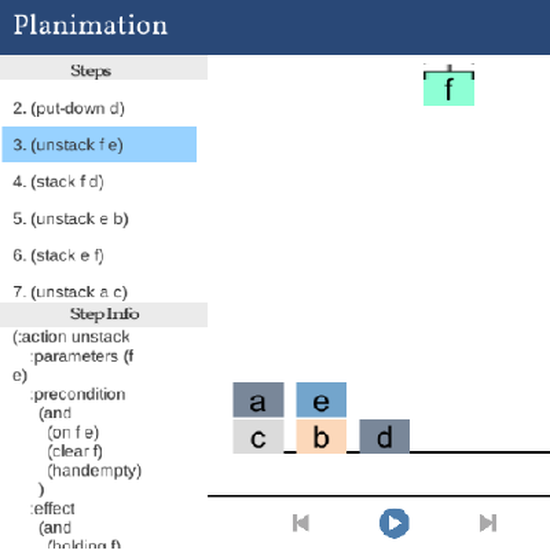
Planimation

Planimation is a framework to visualise sequential solutions of planning problems specified in PDDL

Planners & Competitions

Award-winning classical and numeric planners in several International Planning Competitions 2008 - 2026

Trapper

Invariants, Traps, Un-reachability Certificates, and Dead-end Detection

AI 4 Education

Software to support AI courses in Mel & RMIT Unis (Melbourne, AUS)

Arcade Learning Environment

Classical Planners playing Atari 2600 games as well as Deep Reinforcement Learning

Linear Temporal Logic, Planning and Synthesis

classical planners computing infinite loopy plans, and FOND planners synthesizing controllers expressed as policies.

LAPKT

Lightweight Automated Planning ToolKiT (LAPKT) to build, use or extend basic to advanced Automated Planners

Recent Publications

Quickly discover relevant content by filtering publications.

From Reasoning to Generalization: Knowledge-Augmented LLMs for ARC Benchmark

Recent reasoning-oriented LLMs have demonstrated strong performance on challenging tasks such as mathematics and science examinations. However, core cognitive faculties of human intelligence, such as abstract reasoning and generalization, remain underexplored. To address this, we evaluate recent reasoning-oriented LLMs on the Abstraction and Reasoning Corpus (ARC) benchmark, which explicitly demands both faculties. We formulate ARC as a program synthesis task and propose nine candidate solvers. Experimental results show that repeated-sampling planning-aided code generation (RSPC) achieves the highest test accuracy and demonstrates consistent generalization across most LLMs. To further improve performance, we introduce an ARC solver, Knowledge Augmentation for Abstract Reasoning (KAAR), which encodes core knowledge priors within an ontology that classifies priors into three hierarchical levels based on their dependencies. KAAR progressively expands LLM reasoning capacity by gradually augmenting priors at each level, and invokes RSPC to generate candidate solutions after each augmentation stage. This stage-wise reasoning reduces interference from irrelevant priors and improves LLM performance. Empirical results show that KAAR maintains strong generalization and consistently outperforms non-augmented RSPC across all evaluated LLMs, achieving around 5% absolute gains and up to 64.52% relative improvement. Despite these achievements, ARC remains a challenging benchmark for reasoning-oriented LLMs, highlighting future avenues of progress in LLMs. Our code is available at https://github.com/you68681/kaar.

Mind the Perspective: Let's Reason Recursively for Theory of Mind

Theory of Mind (ToM) reasoning requires inferring agents’ beliefs from partial and asymmetric observations, which remains an open challenge for LLMs. Existing prompting-based approaches improve ToM reasoning through observable-event filtering or temporal belief chains, without explicitly modeling nested beliefs. We introduce RecToM, an inference-time framework for ToM reasoning that models nested beliefs via recursive perspective construction. RecToM constructs each character perspective from the preceding character perspective along the character chain specified by the question, reducing higher-order belief questions to actual-world questions within the final constructed perspective. We further provide a KD45 analysis showing that RecToM’s perspective construction induces a well-formed belief modality beyond simple event filtering. Experiments on ToM benchmarks, including Hi-ToM, Big-ToM, and FanToM, across multiple LLM backbones show that RecToM consistently outperforms recent advanced approaches, achieving state-of-the-art performance. Notably, RecToM reaches 100% accuracy on Hi-ToM with GPT-5.4 and Qwen3.5, a benchmark requiring higher-order ToM reasoning. Our code is available at https://github.com/you68681/rectom.

SVoT: State-aware Visualization-of-Thought for Spatial Reasoning via Reinforcement Learning

Spatial reasoning remains a challenge for Multimodal Large Language Models (MLLMs), as it requires reliable multi-hop inference over both intermediate states and state transitions. Current studies often leave intermediate states unverified and treat state transitions as implicit processes, which limits reliability in multi-hop spatial reasoning. To address this, we propose State-aware Visualization-of-Thought (SVoT), a reinforcement learning framework that generates interleaved, verifiable intermediate states and visualizations. SVoT integrates transition reasoning chains into the generation processes, enabling the model to verify action preconditions and effects through interleaved textual and visual reasoning. We train SVoT via Group Relative Policy Optimization (GRPO), instantiating verification through reward design and evaluating the efficacy of different fine-grained rewards. As existing benchmarks reduce state transitions to single-variable updates, substantially simplifying the problems, we establish five domains by extending classical environments and introducing two novel domains, Pacman and Gather, that require multi-object interactions and numerical reasoning. These domains support systematic evaluation of multi-hop spatial reasoning with quantitative verification of generated intermediate states and transition reasoning. SVoT with transition-aware supervision achieves state-of-the-art performance across the introduced domains, yielding up to a 65% absolute accuracy gain on out-of-distribution test sets.

IPC 2026 Numeric Track: The Panino Solver

Winner of the Satisficing and Agile tracks (Overall) at IPC 2026 Numeric Tracks.

Design and Evaluation of AR-Based Real-Time Feedback System for Kinesthetic Robot Teaching

Best Paper Honourable Mention at DIS 2026.

Past Talks

Towards Model-Based Reasoning in Large Language Models: A Planning Perspective

Invited talk at LM4Plan @ ICAPS 2025 on model-based reasoning in LLMs.

Tractable novelty exploration over Continuous and Discrete Sequential Decision Problems

Seminar talk at the School of Computing and Information Systems, The University of Melbourne, on width-based planning for continuous …

Best-First Width Search for Multi Agent Privacy-preserving Planning

ICAPS 2019 talk on best-first width search for multi-agent privacy-preserving planning.

A Polynomial Planning Algorithm That Beats LAMA and FF

ICAPS 2017 talk on polynomial variants of best-first width search that outperform LAMA and FF empirically.

Planning for Mining Operations with Time and Resource Constraints

ICAPS 2014 talk on planning for mining operations with time-oriented resource constraints.

Students

Current Students

Ph.D.

  • Benjamin Grayland [2026 - current] co-supervised with Prof. Sebastian Sardina and Dr. Steven Korevaar, Topic: Structured Learning approaches for multi-agent problems

  • Giacomo Rosa [2024 - current] co-supervised with Prof. Sebastian Sardina and Dr. Jean Honorio, Topic: Exploration methods for Planning

  • Jiajia Song [2024 - current] co-supervised with Prof. Sebastian Sardina and Dr. William Umboh, Topic: What Makes AI Planning Hard? From Complexity Analysis to Algorithm Design

  • David Adams [2024 - current] co-supervised with Dr. Renata Borovica-Gajic, Topic: Exploration Methods for Databases

  • Qingtan Shen [2023 - current] co-supervised with A/Prof. Artem Polyvyanyy and Dr. Timotheus Kampik, Topic: Multi-agent system discovery

  • Ciao Lei [2022 - current]. co-supervised with Dr. Kris Ehinger and A/Prof Sigfredo Fuentes, Topic: Generalized vision planning problems and their applications in Agriculture

  • Zhiaho Pei [2022 - current]. co-supervized with Dr. Angela Rojas, Dr. Fjalar De Haan and Dr. Enayat A. Moallemi, Topic: Robust decision making for complex systems

Alumni

Ph.D.

Masters

Honours and Awards

Winner - Satisficing Track, Overall (Panino planner)

Overall category: no restriction is placed, both Simple Numeric and Linear Numeric expressions are allowed.

Winner - Agile Track, Overall (Panino planner)

Overall category: no restriction is placed, both Simple Numeric and Linear Numeric expressions are allowed.

Distinguished Program Committee - IJCAI-ECAI 2022

The quality of my reviews were ranked in the top 3% out of 3000+ reviewers.

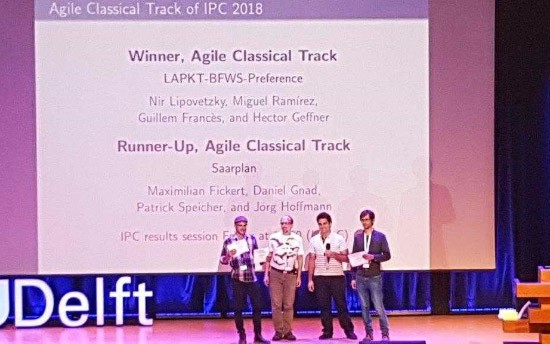
Winner (PROBE planner) and Runner-up (BFWS planner)

Winner - Agile Track | Runner-up - Satisficing Track (BFWS planners)

Winner - Time Track | Runner-Up - Quality and Coverage tracks (LAPKT planners)

Best Dissertation Award (ICAPS)

Text of Award: Nir Lipovetzky takes a new, and very original, look at automated planning: how to reason your way to a plan, instead of searching (blindly or heuristically) for it. First, he has developed a range of novel inference techniques that, combined, produce classical planners that can work with very little backtracking – in many cases none at all – and perform well enough to be awarded at two IPCs. Second, he has invented a novel measure of the hardness of a planning problem, called “width”, and has shown that by properly exploiting it, a simple blind search can do as well as the best-performing heuristic search planners.

Service

Leadership

Conference Chair

  • International Conference on Automated Planning and Scheduling, ICAPS (2025)

Program Chair

  • International Conference on Automated Planning and Scheduling, ICAPS (2019)

Organizing Committee

  • Optimisation and Planning ICAPS 2025 Summer School – Organizer, (2025)

  • AgentsVic Autumn Symposium on Reasoning and Learning for Autonomous Agents – Organizer, (2024)

  • International Conference on Automated Planning and Scheduling – Publicity co-chair, ICAPS (2010)

  • First Unsolvability International Planning Competition – Co-Organizer, UIPC-1 (2016)

  • Heuristics and Search for Domain-independent Planning – Co-Organizer, ICAPS workshop HSDIP (2015,2016,2017,2018)

  • Demonstration track – Co-Chair AAAI (2023)

  • Student Abstract track – Co-Chair, AAAI (2018,2019)

  • Journal Presentation track – Co-Chair ICAPS (2018)

Area Chair

  • Association for the Advancement of Artificial Intelligence, AAAI (2027)

Senior Program Committee

  • Association for the Advancement of Artificial Intelligence, AAAI (2020,2021,2022,2023)
  • International Joint Conferences on Artificial Intelligence IJCAI (2021,2023)
  • Association for Computational Linguistics (ACL) conference Rolling Review, Area Chair, (Jan 2026)

Program Committee

  • International Joint Conferences on Artificial Intelligence IJCAI (2011,2013,2015,2017,2018,2020,2022)

  • Association for the Advancement of Artificial Intelligence, AAAI (2013,2015,2016,2017,2018,2019)

  • European Conference on Artificial Intelligence, ECAI (2014,2016)

  • International Conference on Automated Planning and Scheduling, ICAPS (2015,2016,2017,2018,2020)

  • Symposium on Combinatorial Search SOCS (2020,2021,2022,2023)

Reviewer

  • Journal of Artificial Intelligence Research, JAIR

  • Reviewer Artificial Intelligence, Elsevier AIJ

  • Reviewer Communications of the ACM, CACM

Other

  • ICAPS Awards Committee (2024,2025)

Teaching

  • Master of Artificial Intelligence - Online (Course Director), at The University of Melbourne, 2025 - ongoing

  • Pacman Capture the flag Inter-University Contest, run for Unimelb AI coure and Hall of Fame contest, 2016 - current

  • AI Planning for Autonomy (Lecturer), at M.Sc. AI specialization, The University of Melbourne, 2016 - current

  • Data Structures and Algorithms (Lecturer), at The University of Melbourne, 2016 - current

  • Software Agents (Lecturer), at M.Sc. Software, The University of Melbourne, 2013, 2014, 2015

  • Autonomous Systems, at M.Sc. Intelligent Interactive Systems, University Pompeu Fabra, 2012

  • Advanced course on AI: workshop on RoboSoccer simulator, at Polytechnic School, University Pompeu Fabra, 2009, 2010, 2011

  • Artificial Intelligence course, at Polytechnic School, University Pompeu Fabra, 2010, 2011

  • Introduction to Data Structures and Algorithms course, at Polytechnic School, University Pompeu Fabra, 2008

  • Programming course, at Polytechnic School, University Pompeu Fabra, 2008, 2009, 2010, 2011

Contact